Q1: Какова точность ориентации IMU U3500?
A: U3500 обеспечивает точность по тангажу и крену 0.1° (тип.) и точность по курсу 0.1–2° в зависимости от режима (AHRS или 6DOF).


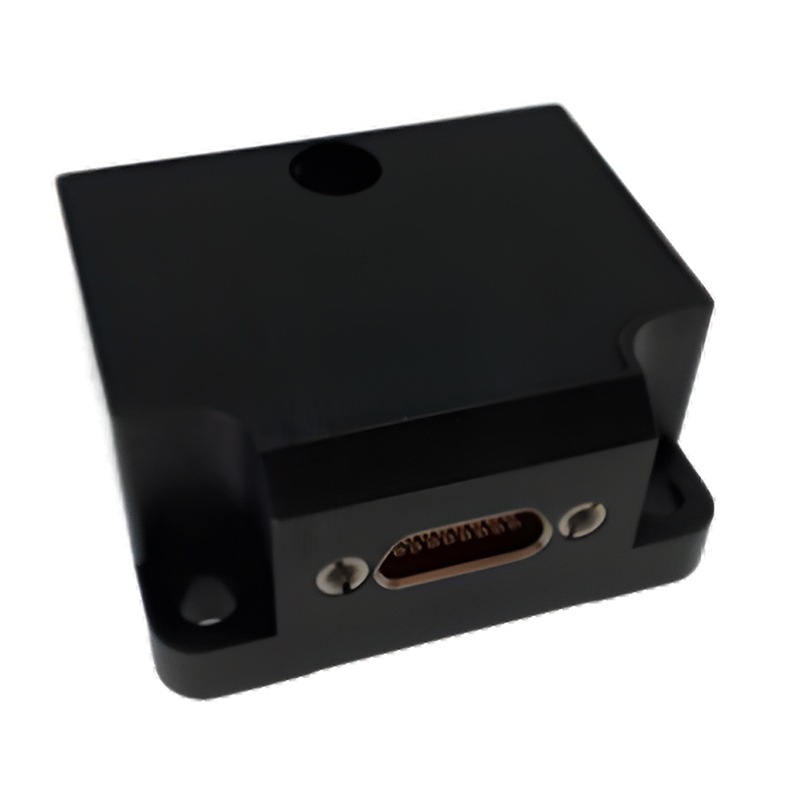
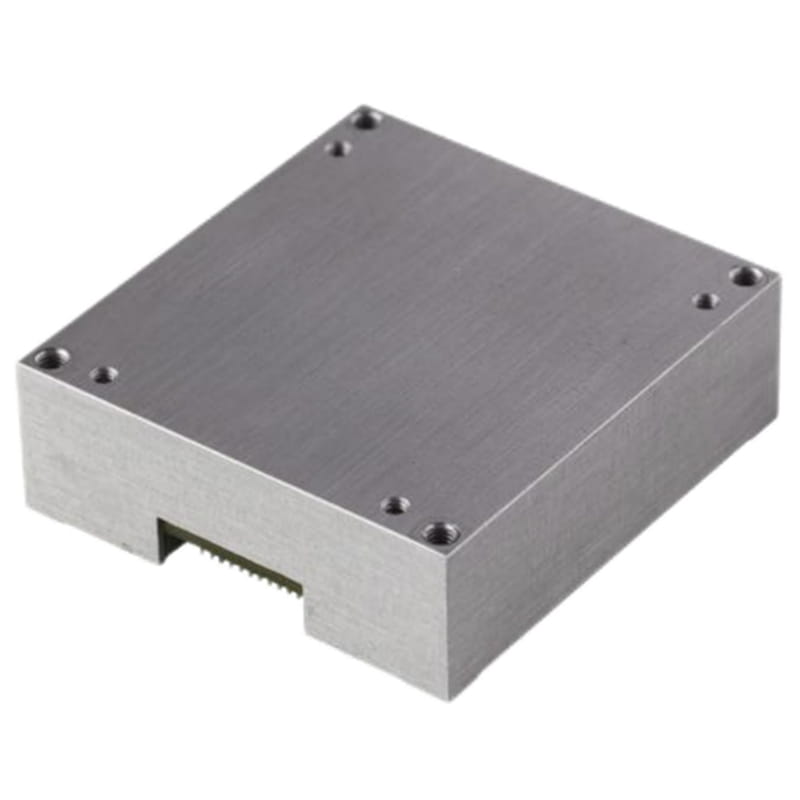
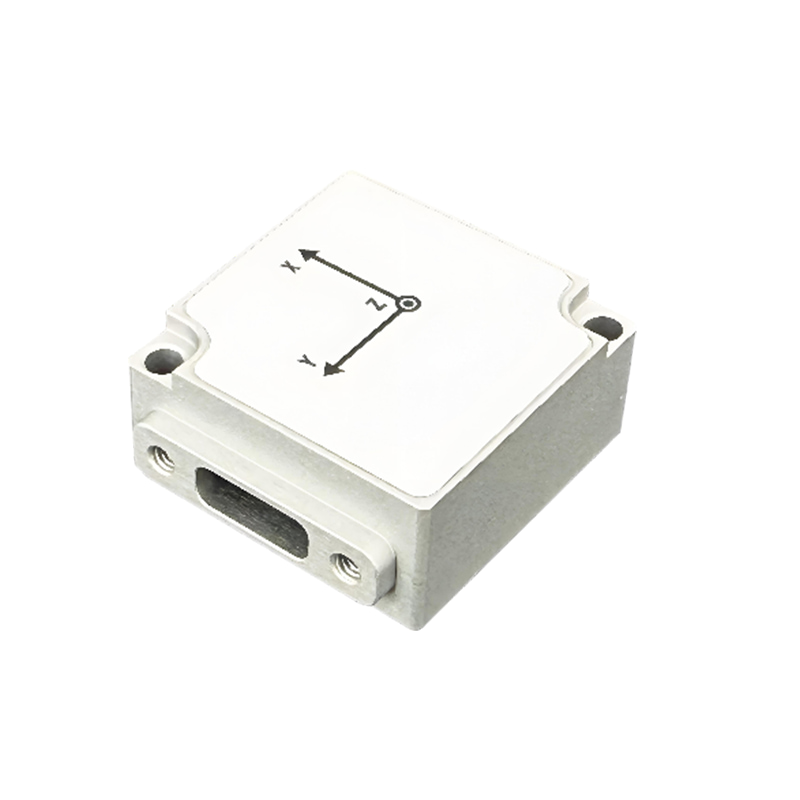
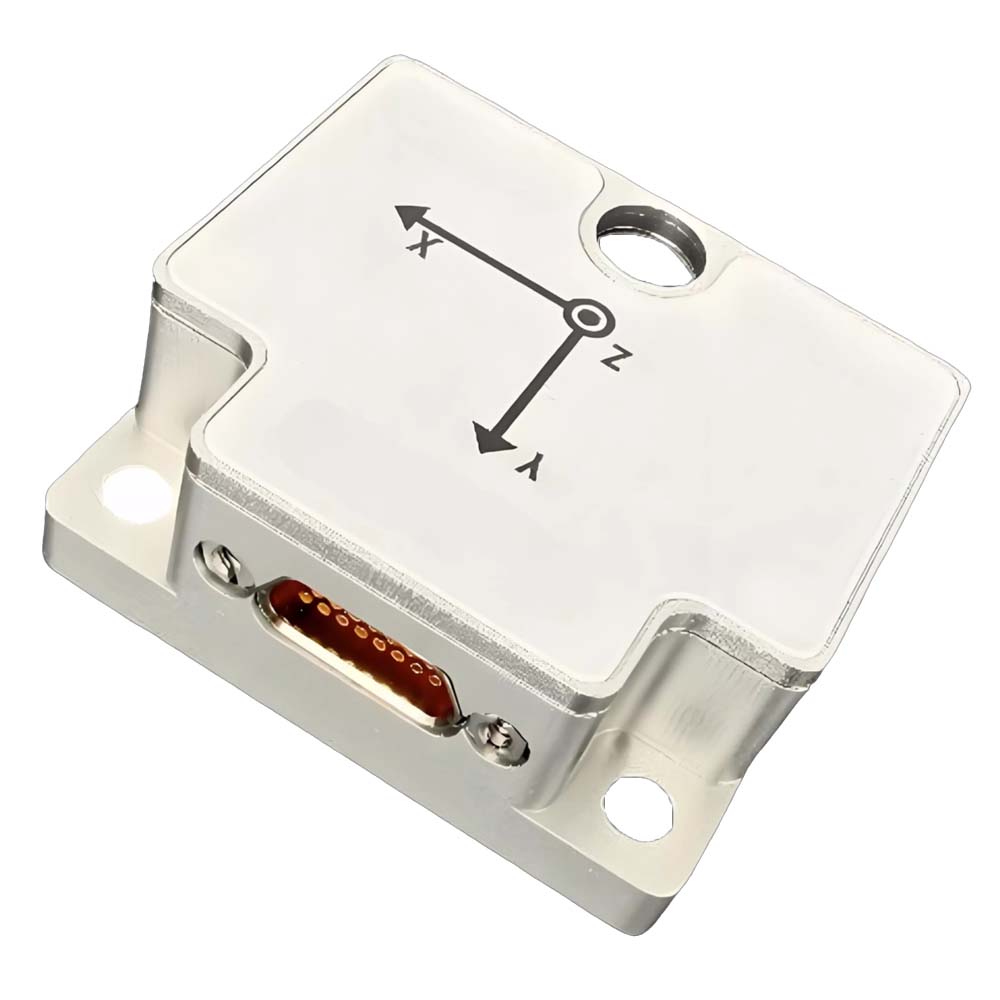
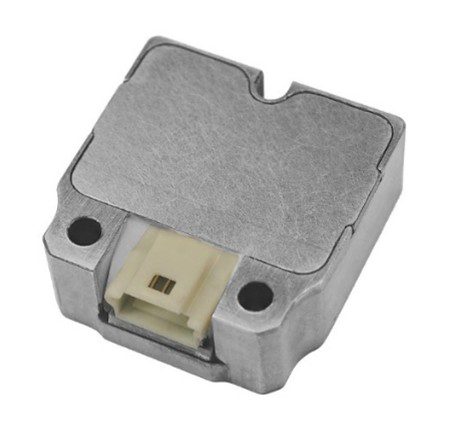
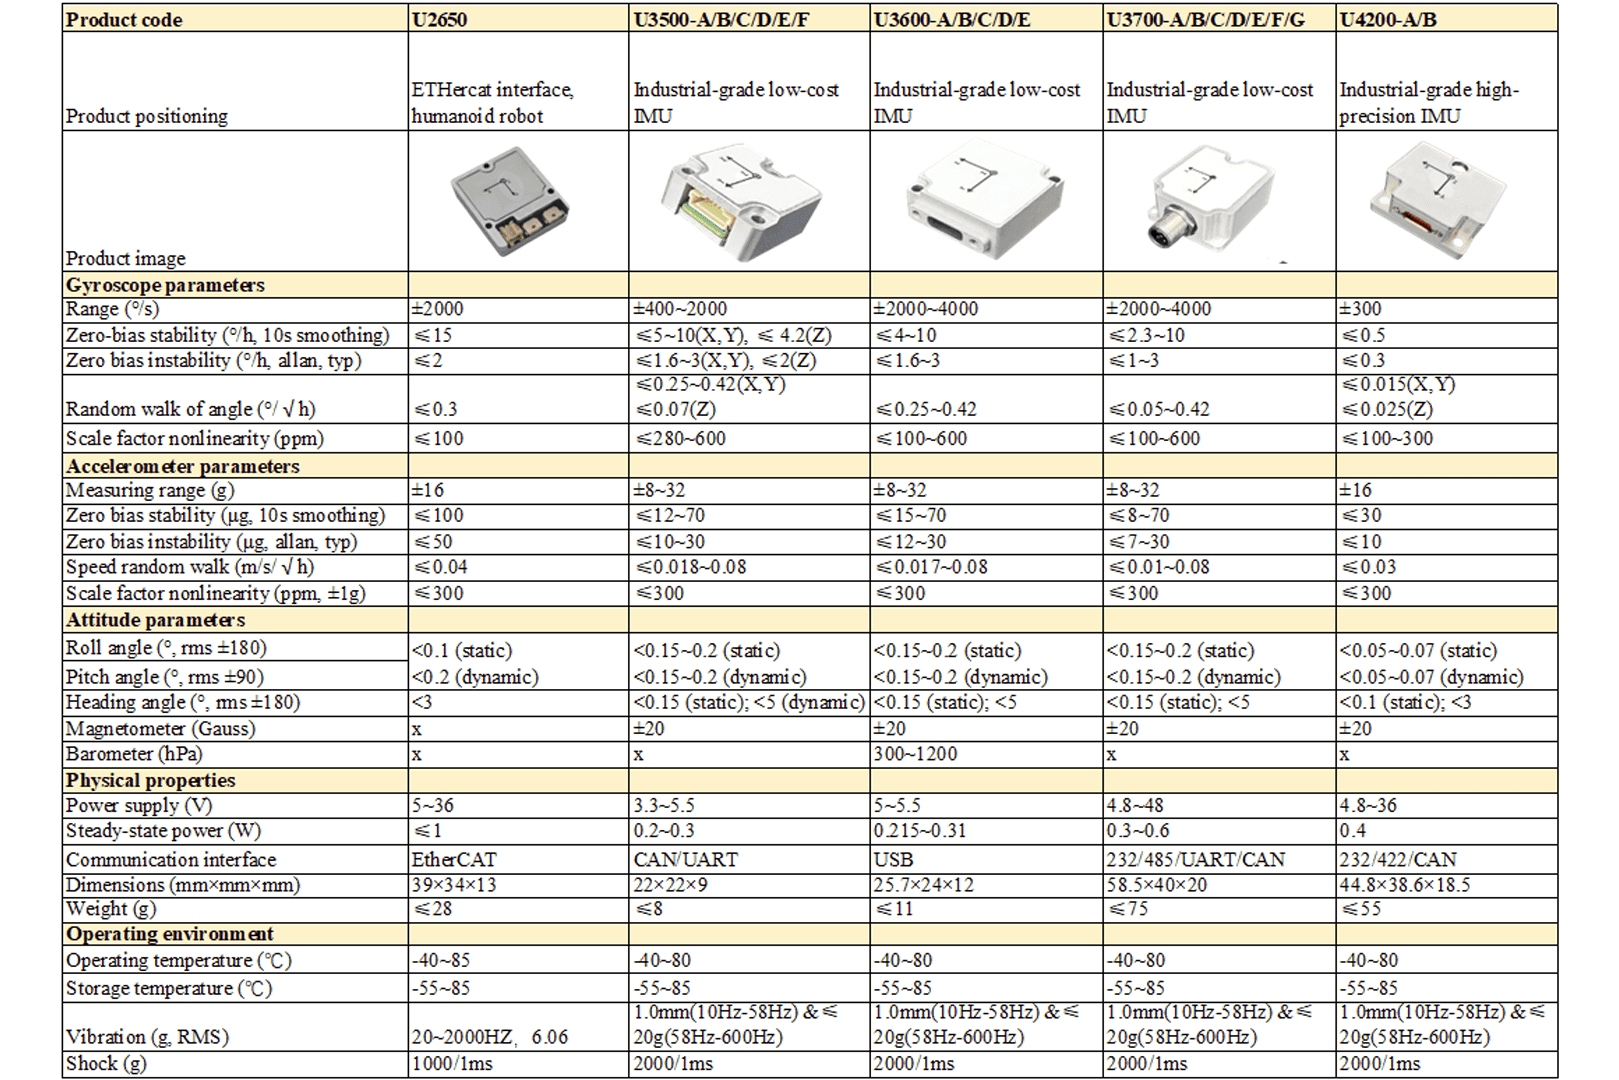
Серия U3500 представляет собой датчик IMU/VRU/AHRS, состоящий из высокопроизводительного MEMS-IMU, магнитометра и усиленного одноосевого гироскопа.
Он оснащен самостоятельно разработанным адаптивным расширенным фильтром Калмана, алгоритмом динамического анализа шума IMU и алгоритмом анализа состояния движения носителя, что позволяет обеспечивать точность угла ориентации в условиях высокой динамики и уменьшать дрейф угла курса.
Каждый датчик перед отправкой с завода проходит точную компенсацию, включая температурную компенсацию, нулевое смещение, масштабный коэффициент и перекрестную ось.
Датчики серии U3500 передают данные через интерфейс UART и имеют широкие пользовательские настройки.
Если требуется интерфейс CAN, пользователи должны самостоятельно интегрировать схему приемопередатчика CAN.
Серия U3500 поддерживает внешнее срабатывание, синхронизацию времени с радаром и камерой, а также GUI-оценку, включая конфигурацию, отображение, обновление прошивки и запись данных.
Номер детали, :
U3500
Минимальный заказ (MOQ) :
1
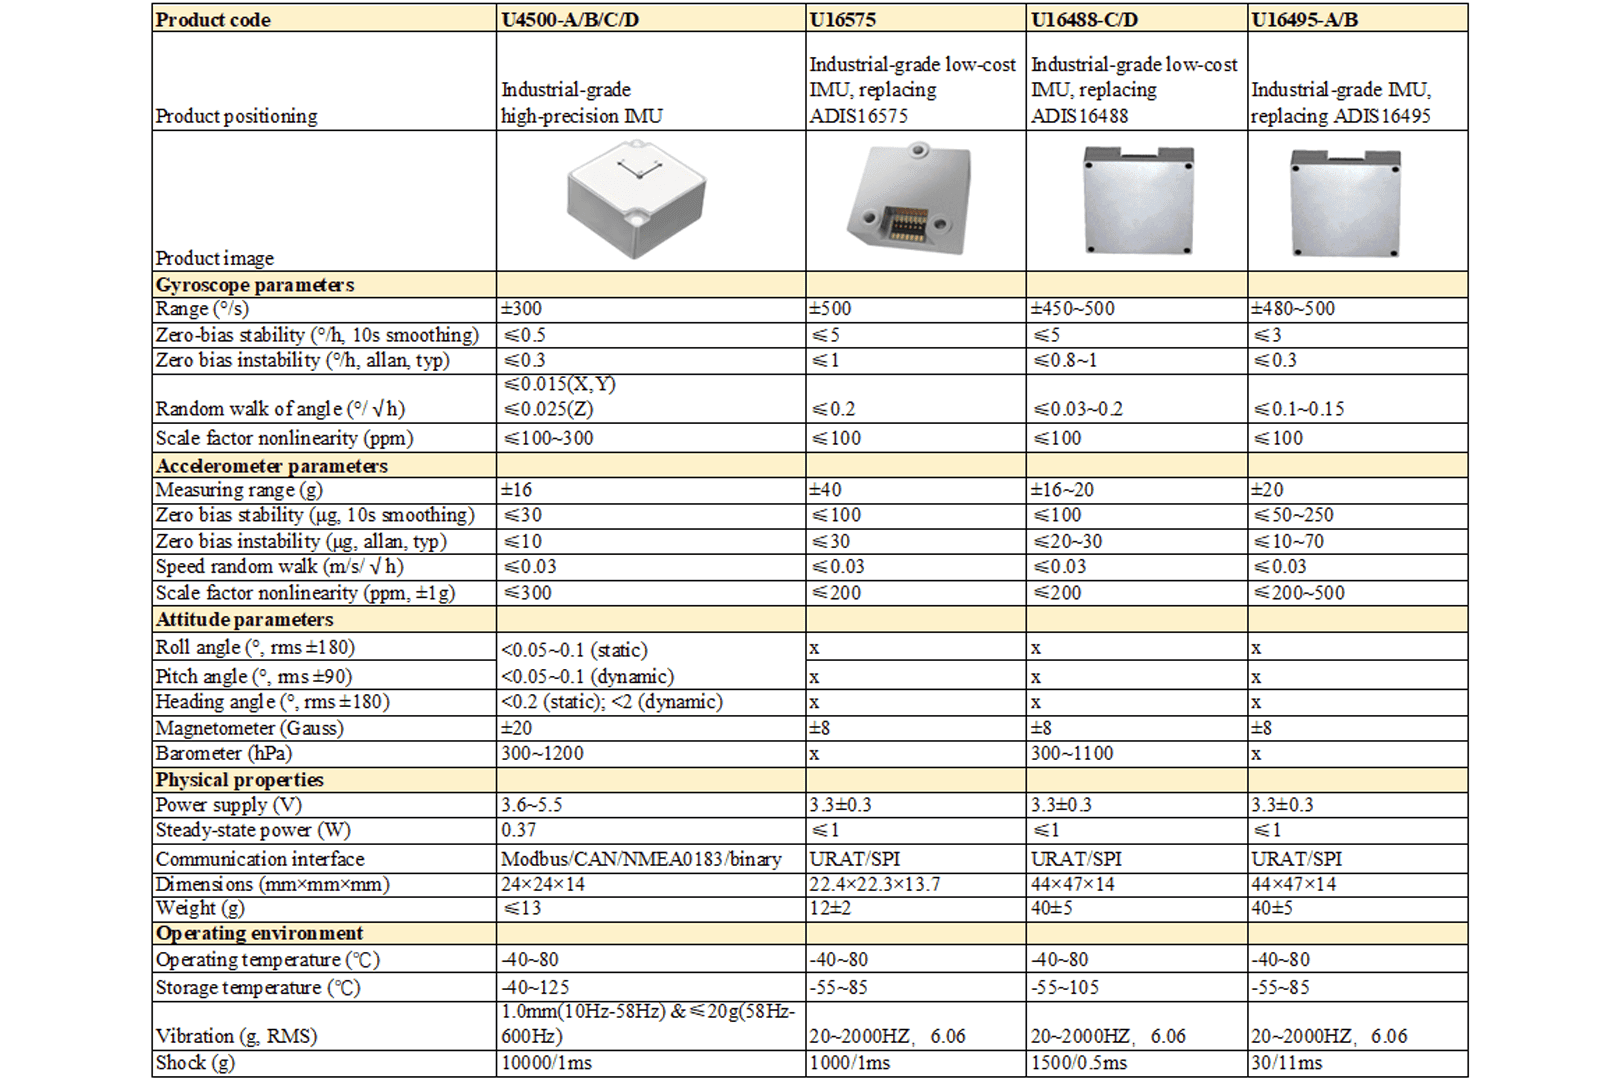
| Attitude Precision | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Pitch (±90°) / Roll (±180°) (static) | 0.15(nom), 0.2(max) | ° | |||||
| Pitch (±90°) / Roll (±180°) (dynamic) | 0.15(nom), 0.2(max) | ° | |||||
| Yaw (±180°) static drift 2hrs (6DOF) ① | 0.15(nom), 0.2(max) | ° | |||||
| Yaw (±180°) dynamic drift (6DOF) ② | 9 | 5 | ° | ||||
| Magnetic assist (AHRS)③ | / | / | / | 2(nom), 3(max) | / | 2(nom), 3(max) | ° |
| Yaw rotation error (6DOF) (rotation under 100°/s)④ | 3(max) | <0.8(nom), 1.5(max) | 1(max) | ° | |||
| Resolution | 0.01 | ° | |||||
| Notes: ① The module was kept stationary for 2 hours. ② The measurement was taken after the module had been moving on an indoor cleaning robot for 1 hour, 1σ. ③ After geomagnetic calibration, the measurement was taken in the absence of surrounding magnetic field interference, and the product needed to be configured in AHRS mode. ④ The turntable was rotated continuously for 10 revolutions, resulting in cumulative error in the heading angle. |
|||||||
| Gyroscope | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Measurement range | ±2000 | ±400 / ±2000(max) | ±4000 | °/s | |||
| Resolution | 16 | 20 | bit | ||||
| Scale factor (100°/s)① | <600(nom) 800(max) |
<280(nom) 300(max) |
<250(nom) 300(max) |
ppm | |||
| Nonlinearity② | ±0.05 | %Fs | |||||
| 3dB Bandwidth | 80 | 80(nom) 400(max) | Hz | ||||
| Sampling rate | 1000 | Hz | |||||
| Zero bias instability (Allan, 1σ) | 3 | X,Y: 3 Z: 2 |
X,Y: 1.6 Z: 2 |
1.5 | °/h | ||
| Zero bias stability (10s, 1σ) | 10 | X,Y: 10 Z: 4.2 |
X,Y: 5 Z: 4.2 |
3.5 | °/h | ||
| Zero bias repeatability (1σ) | 14.5 | X,Y: 14.5 Z: 5.5 |
X,Y: 8.2 Z: 5.5 |
3 | °/h | ||
| Angle random walk (Allan, 1σ) | 0.42 | X,Y: 0.42 Z: 0.07 |
X,Y: 0.25 Z: 0.07 |
0.08 | °/√h | ||
| Full temp zero bias -40~85℃ | 0.1(nom), 0.3(max) | ||||||
| Accelerometer sensitivity | 0.1 | 0.05 | °/s/g | ||||
| Notes: ① Rotate the turntable 10 times in both directions and take the average measurement. ② Maximum deviation from the best-fit line within the specified range. |
|||||||
| Accelerometer | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Measurement range | 12 | 8 / 32(max) | g | ||||
| Resolution | 16 | 20 | bit | ||||
| Initial bias drift① | 5(max) | 2(nom) 5(max) | mg | ||||
| Nonlinearity | 0.5 | 0.01 | %Fs | ||||
| 3dB Bandwidth | 145 | 90(nom) 400(max) | Hz | ||||
| Sampling rate | 1600 | 1000 | Hz | ||||
| Zero bias instability (Allan, 1σ) | 0.03 | 0.018 | 0.01 | mg | |||
| Zero bias stability (10s, 1σ) | 0.07 | 0.035 | 0.012 | mg | |||
| Zero bias repeatability (1σ) | 0.24 | 0.13 | 0.09 | mg | |||
| Angle random walk (Allan, 1σ) | 0.08 | 0.04 | 0.017 | m/s/√h | |||
| Full temp zero bias -40-85℃ | 3(nom) ~10(max) | mg | |||||
| Notes: ① This value will change after the user installs it, and the actual value shall prevail. |
|||||||
| Magnetometer | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Range | / | / | / | 20 | / | 20 | Gauss |
| Sampling | / | / | / | 200 | / | 200 | Hz |
| Linearity | / | / | / | 0.1 | / | 0.1 | Fs% |
| Temperature Sensor | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Range | -104(min) – 150(max) | ℃ | |||||
| Offset error | ±1 | K | |||||
| Mechanical/Environment | U3500-A | U3500-B | U3500-C | U3500-D | U3500-E | U3500-F | Unit |
| Power supply | 3.3 — 5.5 / 6.5(max) | V | |||||
| IO To GND | -0.3 ~ 5 | V | |||||
| Power consumption | 240 | 245 | 300 | 200 | mW | ||
| Working/Storage temperature | -40 ~ +85 | ℃ | |||||
| Gyroscope range | ±2000 | Z: ±400① XY: ±2000 | ±2000(nom) ±4000(nom) | °/s | |||
| Accelerometer range | ±12(nom) ±24(max) | ±8(nom) ±32(max) | g | ||||
| Starting time② | 2 | s | |||||
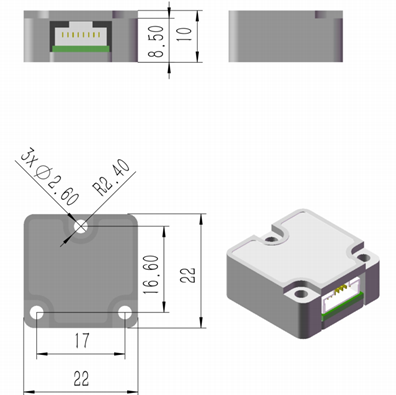
| Size | Molex interface: 22*22*10 Board-to-board interface: 22*22*9 |
mm | |||||
| Weight | <8 | g | |||||
| Shell material and process | Aluminum alloy CNC | ||||||
| Assembling screws | M2.5 | ||||||
| Connector model | Molex connector: Molex 5015680807 Board to board connector: 2x8P pin spacing of 1mm |
||||||
| Anti-Vibration | 1.0mm(10Hz-58Hz) & ≤20g(58Hz-600Hz) | ||||||
| Shock (duration <1ms) | 2000 | g | |||||
| Environment protection | RoHS Directive 2011/65/EU | ||||||
| EMC | LVD Directive 2014/35/EU | ||||||
| Drop test | Free fall 3 times on a 75cm high experimental platform | ||||||
| Temperature shock | Raise the temperature from -40 to 85 ℃ within 1h, 5 times | ||||||
| Notes: ① U3500-B/C/D are equipped with a high-vibration-resistance single-axis gyroscope, and it performs best when the range is <400°/s. ② The startup time refers to the time from when the system is powered on to when valid data is output. During this period, the module should be kept stationary. |
|||||||
| Interface | Parameter | Condition | Min | Normal | Max | Unit |
| UART (TTL) | Baud-rate | 9600 | 115200 | 921600 | bps | |
| Starting position | 0 | 1 | bit | |||
| Data length | 0 | 8 | bits | |||
| Stop bit | 1 | bit | ||||
| Checksum | None | bit | ||||
| Output frame rate① | 0 | 100 | 1000 | Hz | ||
| Logic voltage | High/Low | 2 | 3.3 | 3.6 / 0.6 | V | |
| CAN | Baud-rate② | 125 | 500 | 1000 | kbps | |
| Output frame rate③ | 5 | 100 | 200 | Hz | ||
| Logic voltage | High/Low | 2 | 3.3 | 3.6 / 0.6 | V | |
| IO | Logic voltage | High/Low | 2 | 0.6 | V | |
| Delay (trigger function)④ | from trigger generation to data transmission | 800 | us | |||
| Notes: ① The sensor supports data output at 1, 5, 10, 50, 100, 200, 250, 500, and 1000Hz. ② The baud rates supported by CAN communication are 125K, 250K, 500K, and 1000K. ③ The sensor’s CAN communication supports data output at 5, 10, 50, 100, 200, and 1000Hz. ④ For multi-functional IO operations and configurations, please refer to the instruction and programming manual. |
||||||


A: U3500 обеспечивает точность по тангажу и крену 0.1° (тип.) и точность по курсу 0.1–2° в зависимости от режима (AHRS или 6DOF).
A: Да. Рабочая температура составляет от -40℃ до +80℃, изделие имеет сертификацию RoHS и CE, высокую виброустойчивость и выдерживает удар 2000g.
A: Навигация БПЛА, беспилотные роботы, прецизионные приборы, стабилизация платформ, подземные приборы и строительная техника.